Skip to content

PHYSICAL AI / ROBOTICS

Robots at work in the real world.Starting in simulation.

TeamZ develops and evaluates physical AI. Through in-house simulation research and joint development, we work toward robots that can operate in real environments.

ROS2 / Isaac Sim / LeRobot

FROM OUR SIMULATION RESEARCHSIMULATION

Lunar rover: around the rocks to the observation site

Different rock layouts, different detours. Independent demo inspired by public LUPEX information. Ideal sensors; no hardware validation. Japanese video labels.

ENGINEERING EXPERIENCE

Supporting a robotics company with bring-up testing, simulation and SLAM development.

See our role →(Japanese)

OUR APPROACH

Explore in-house. Bring the findings to joint development.

About TeamZ →(Japanese)

RESEARCH & VALIDATION

Build. Measure. Improve.

Explore our work →
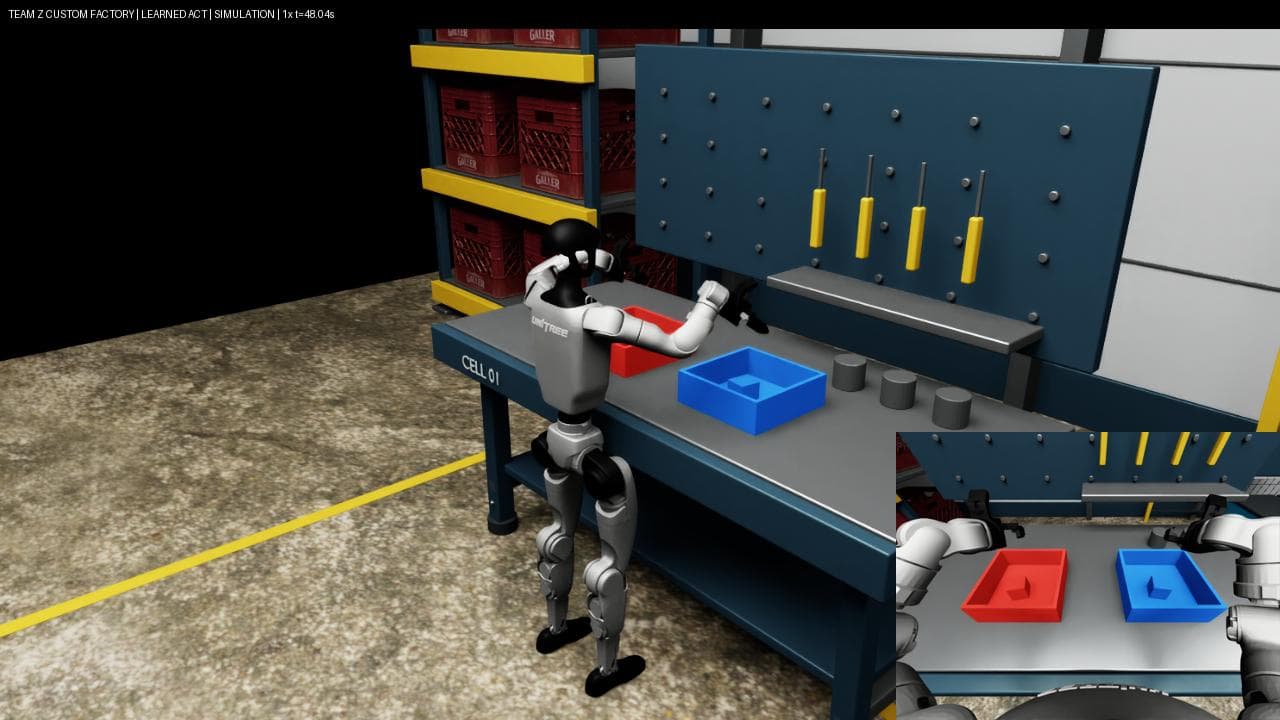
Learning to sort parts from images.

IN-HOUSE RESEARCH / SIMULATION ONLY

Learning to sort parts from images.

48 / 50

successful trials on held-out placements

We evaluated ACT-based sorting with G1: a fixed base, stationary parts and position offsets within ±10 mm.

Conditions and results →(Japanese)
Pick up a box, walk and place it.

IN-HOUSE RESEARCH / SIMULATION ONLY

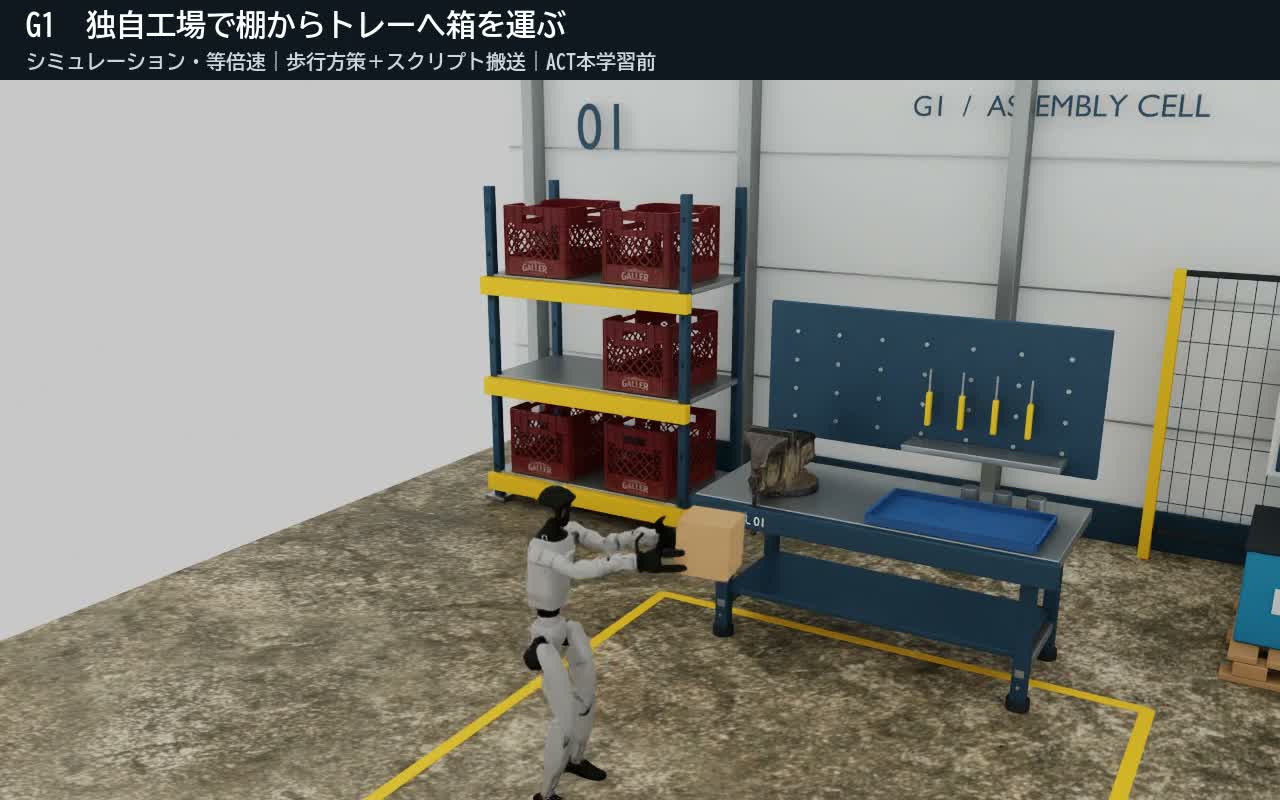
Pick up a box, walk and place it.

3 / 3 → 1 / 10

fixed placement → varied placements

We integrated a walking policy with two-hand support control. Placement and settling succeeded at a fixed position but degraded when positions changed.

Conditions and results →
Observe the surroundings and navigate.

IN-HOUSE RESEARCH / SIMULATION ONLY

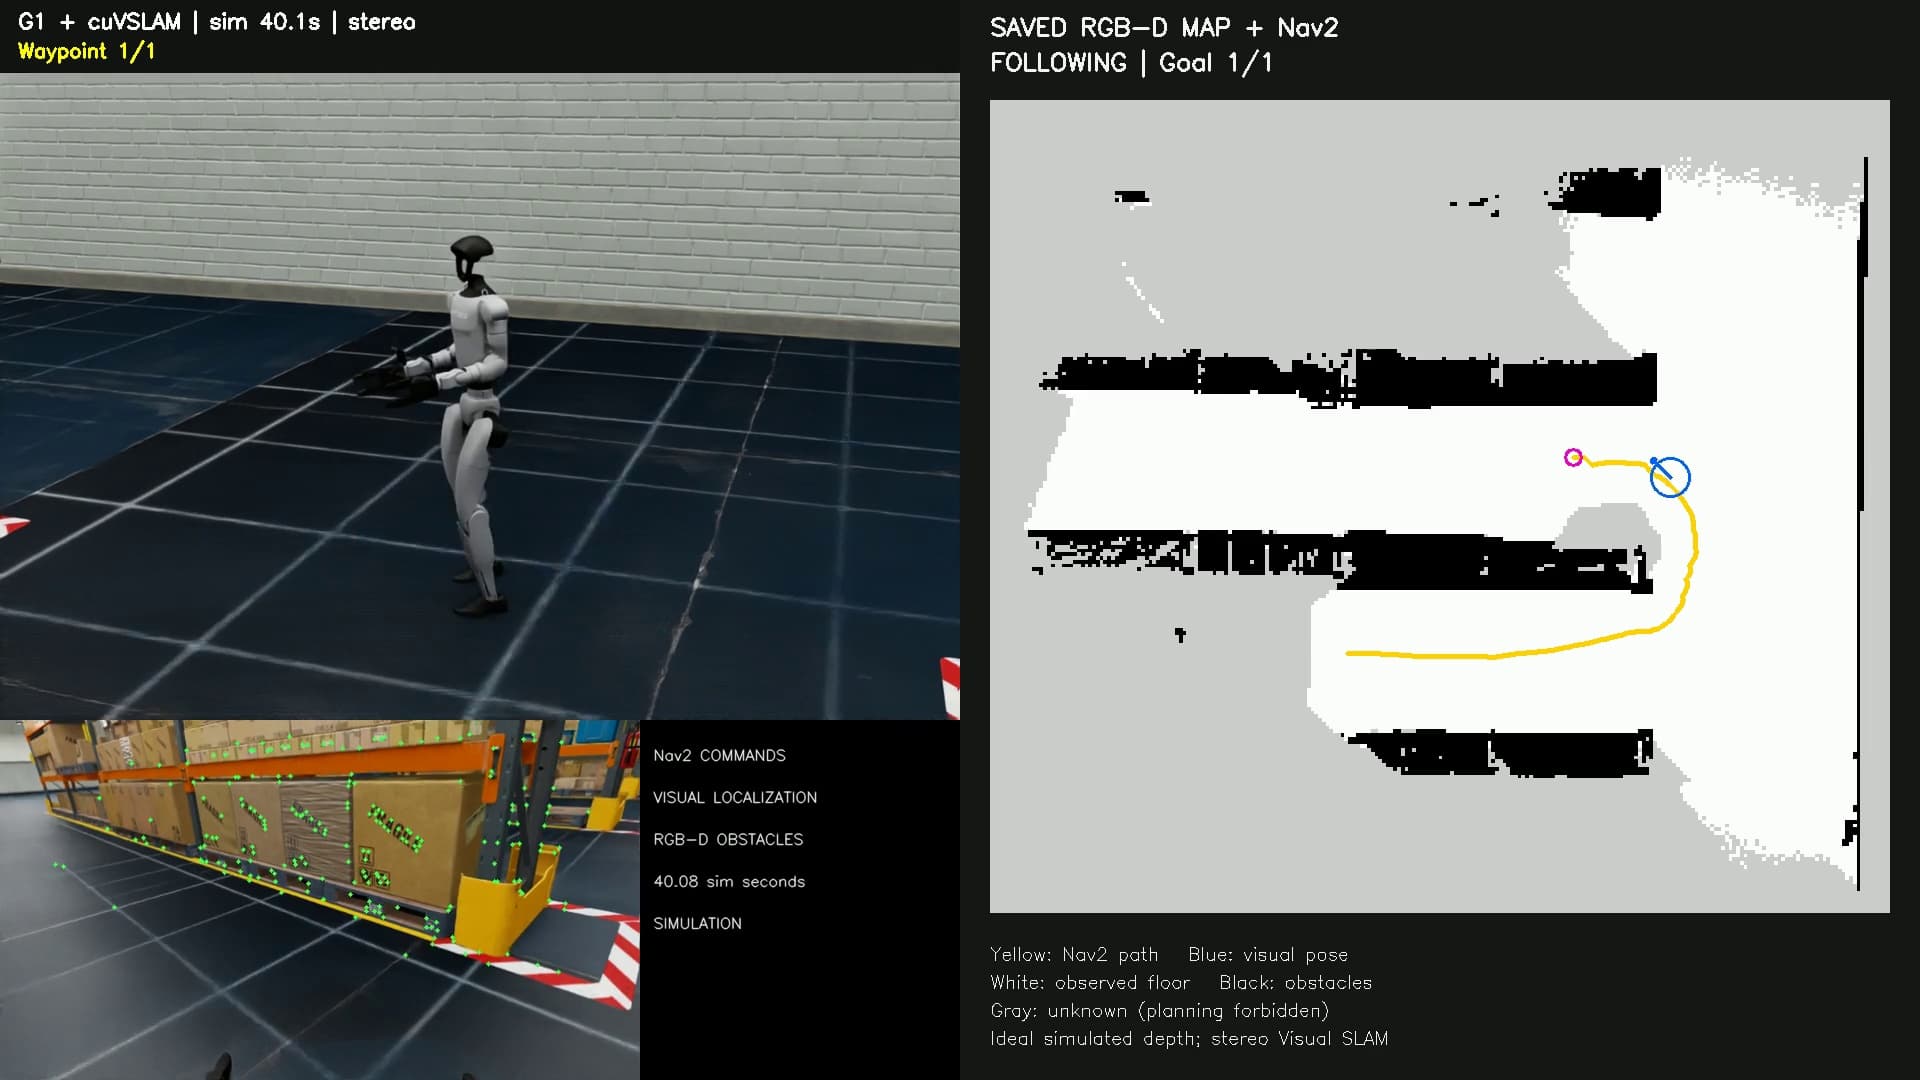
Observe the surroundings and navigate.

Visual SLAM × Nav2

connecting perception and navigation

We connected localization and path planning in a virtual warehouse, navigating around shelves to reach and stop at a goal.

Conditions and results →

Results apply to the stated test conditions. We also document failures and unresolved questions.

Read our engineering notes →

JOINT DEVELOPMENT

Turn robotics challenges into scoped implementation and testing.

We review the task and development environment, agree on scope, evaluation conditions and timing, then start with a small implementation and test. Results guide the next decision.

01Isaac Sim / ROS2

Build the test environment

Configure the workspace, objects and robot to test behavior under different conditions.

02LeRobot / ROS2

Connect learning and control

Prepare data, connect models and control, and check behavior within the agreed software scope.

03Conditions / Logs / Results

Evaluate robot behavior

Record successes and failures, investigate causes and remaining issues, then discuss further development, hardware tests, revisions or stopping.

JOIN OUR TEAM

Build the future of robots at work with us.

Simulation, learning, control and ROS 2 integration. Help turn experiments into the team's engineering knowledge.

Explore careers →(Japanese)

CONTACT

Discuss development and validation

Tell us about your task, development environment and current challenges. We will discuss the scope of work and evaluation conditions.

Open contact form →

Usually reply within 2–3 business days

Contact us